Live screenshot
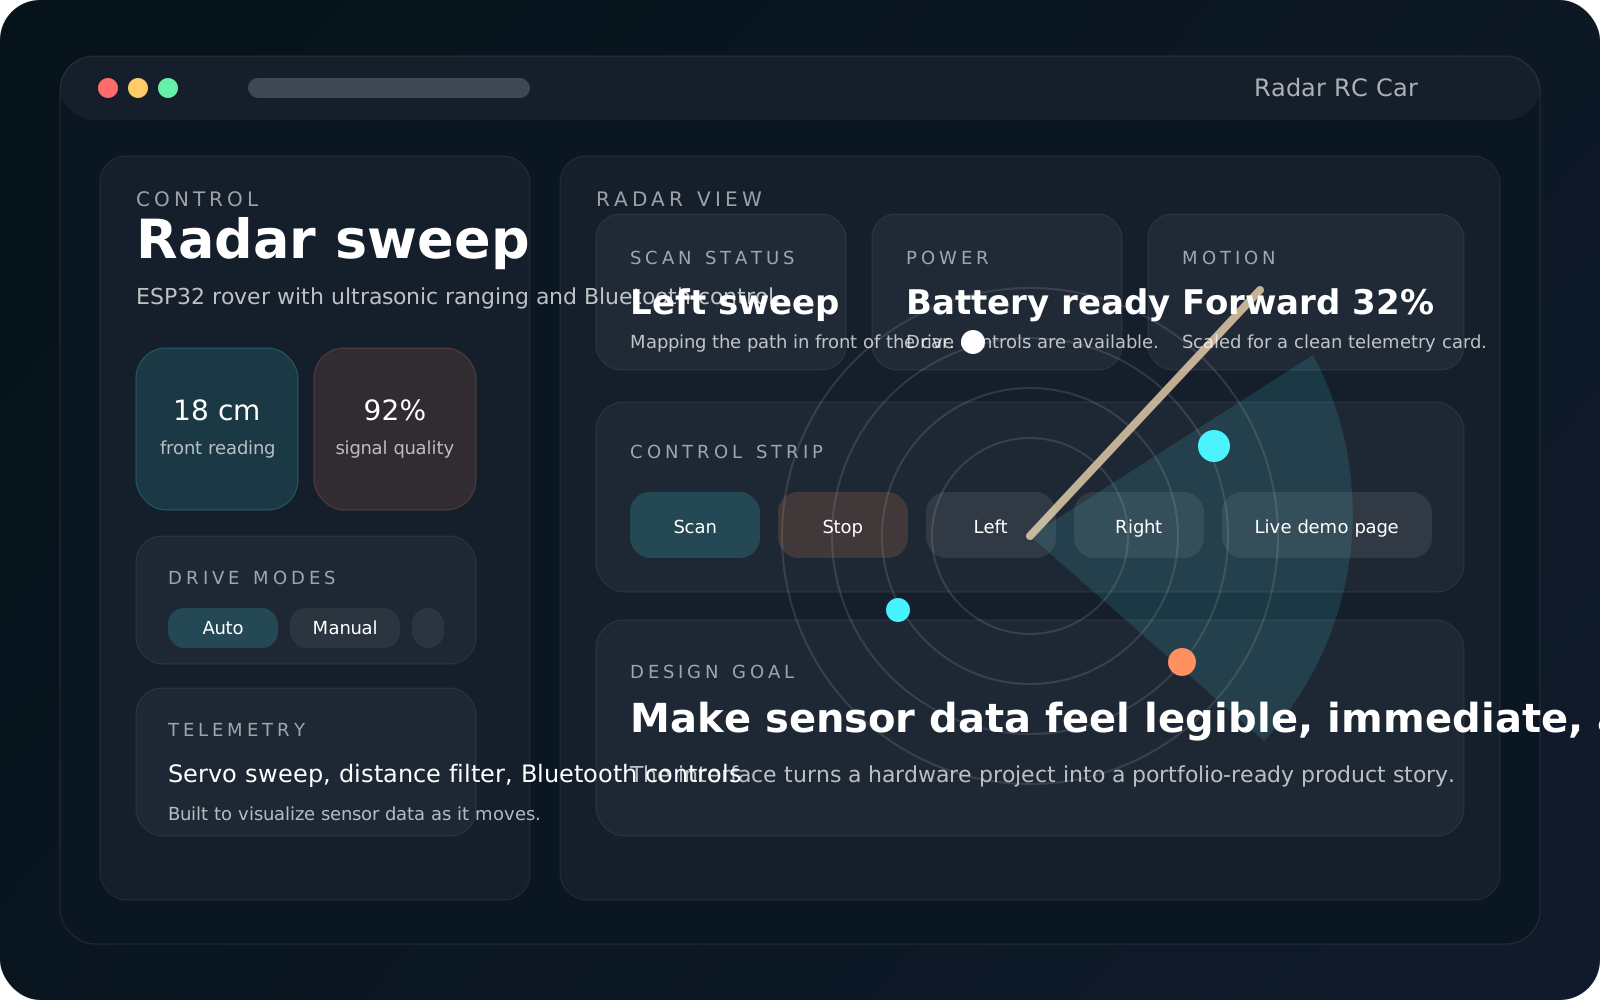
The radar view turns the rover into something easy to demonstrate, explain, and remember in a portfolio review.
An ESP32 rover with servo scan, ultrasonic ranging, and Bluetooth control presented through a radar-style interface.
The radar view turns the rover into something easy to demonstrate, explain, and remember in a portfolio review.
This project helps the portfolio show hardware, sensing, and interface design in the same story.
A rover can feel abstract until the feedback is translated into something human-readable. The radar interface helps explain what the car sees, where the scan is moving, and how the control state changes over time.
The page treats the hardware like a product demo, with cards for telemetry, clear control modes, and a sweep arc that tells the story visually. The result is easier to present than a bare serial log or a block of code.
The project becomes the kind of build that a reviewer can understand in seconds while still seeing enough detail to appreciate the embedded and UI work behind it.